Robotics is a cornerstone for this century’s innovations. From robot nurses to your own personal assistant, most robots need to know: ‘where is it?’ ‘Where should it go?’ And ‘how to get there?’ Without answers to these questions a robot cannot do much.
Claire Farrugia (supervised by Dr Marvin Bugeja) developed an algorithm that allows the robot to move on its own and build a map of its environment while continuously estimating its location within this map. A system known as Active-SLAM (Simultaneous Localization and Mapping), allows the robot to explore an area on its own by mapping its surroundings and figuring out where it is. This system is more efficient than previous systems (regular SLAM) where the robot is moved manually with a joystick.
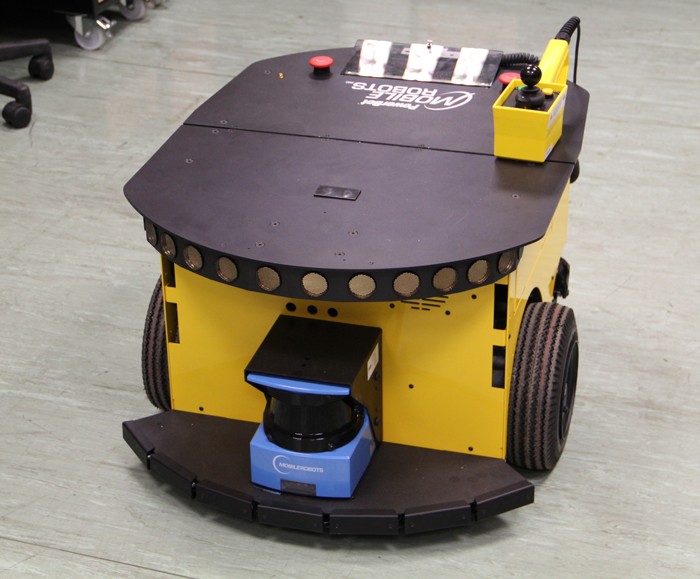
Farrugia focused on answering how a robot gets from point A to B, which is more complicated than it sounds. The robot needs to map its area, avoid obstacles, and steer away from obstacles placed in its path — like a human on a stroll.Farrugia used a two-wheeled robot which could sense its surroundings with an on-board laser (LIDAR) and sonar. She combined the ultrasound and laser data to make a more accurate map and for the robot to pinpoint its own position on it.
The robot then needs to decide where it wants to go. Once it has decided, it needs to plan its path around any obstacles to get there.
To make the robot move safely around the lab on its own, Farrugia built the D*Lite algorithm, which helps a robot move towards its destination in the shortest distance, while dodging obstacles quickly to return to its original path. Farrugia could follow the robot’s movement using a custom-built software package that let her command the robot to whichever destination she desired.
Algorithms like Farrugia’s, that allow robots to explore areas on their own steam, are necessary for robots that need to go to areas that are risky or expensive for people to go. Robots that can plan flights or map abandoned underground mines and deep seas have already been developed.
This research was performed as part of the course in Bachelor of Engineering (Hons) within the Faculty of Engineering at the University of Malta. It was presented at the IET Present Around the World (PATW) Competition 2014 organised annually by the Malta Group of Professional Engineering Institutions (MGPEI).

Comments are closed for this article!